Real time weed detection [Professional]
Introduction
Weed control is a key element in precision agriculture. In computer vision, variety of techniques are developed to detect, identify and locate weeds in different crops. Chemical weed control is widely practiced to reduce infection rates and improve crops. Targeting weeds and minimizing the exposure of the crops to sprayed agrochemicals results in high quality and safe food production.
Related Smart Farming Technology Products
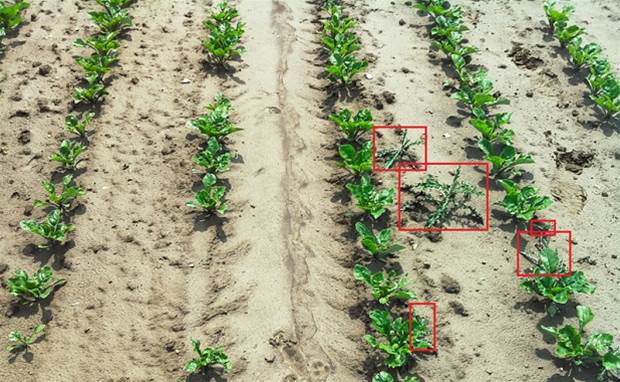
Intelligent Spot Spraying System by Agrifac[2]
WEEDit[7]
WEEDit is a plant detection technology at applies chemical only to the target instead of spraying bare ground. Intelligent sensors sample the ground 40,000 times per second searching for living plant matter up to speeds of 15mph. Ground speed is measured and will adjust application timing so that the target is within the spray pattern.
Blue River – See & Spray[8]
Related Scientific Articles
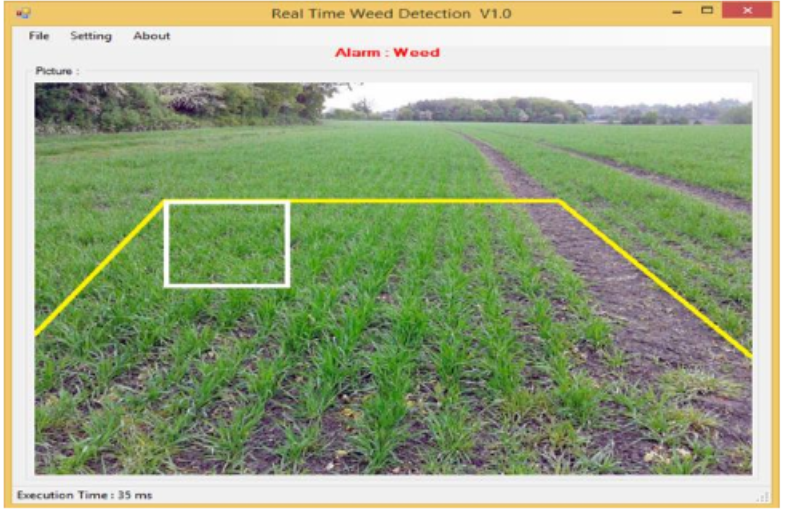
Real Time Weed Detection using a Boosted Cascadeof Simple Features[3]
In this article, the authors present a real-time new weed detection method, through an embedded monocular vision. Their approach was based on the use of a cascade of discriminative classifiers formed by the Haar-like features.[3]
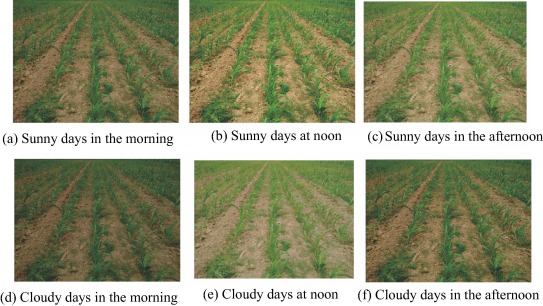
Weed detection using image processing under different illumination for site-specific areas spraying[5]
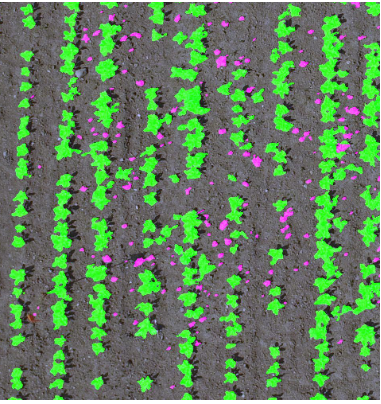
To avoid the influence of different illumination on images, this paper adopts the color model and then proposes component to gray images; the vertical projection method and the linear scanning method are combined to quickly identify the center line of the crop rows; the classic Weeds Infestation Rate (WIR) is modified to decrease the computational complexity and the improved horizontal scanning method is taken to calculate within cells; finally, Modified Weeds Infestation Rate (MWIR) is used to realize real-time decision through the minimum error ratio of Bayesian decision under normal distribution. The experimental results show that the accuracy of this algorithm is 92.5%, which exceeds the BP algorithm and SVM algorithm. [5]
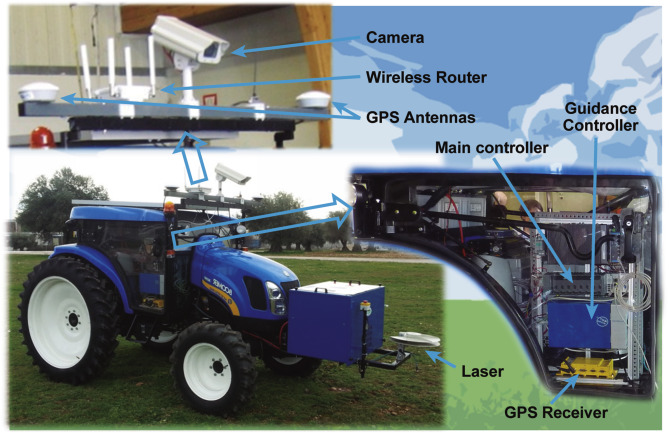
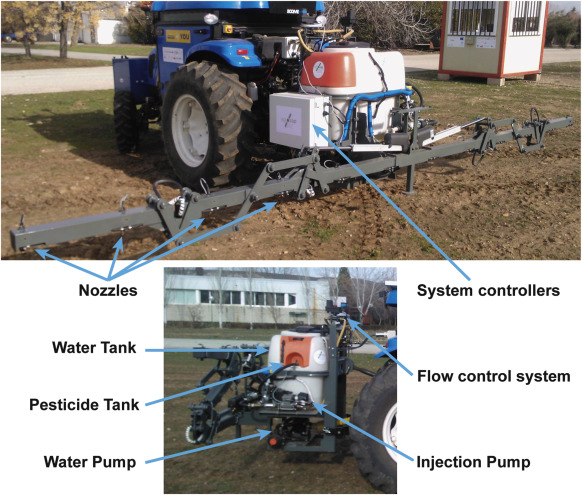
Autonomous systems for precise spraying – Evaluation of a robotised patch sprayer[6]
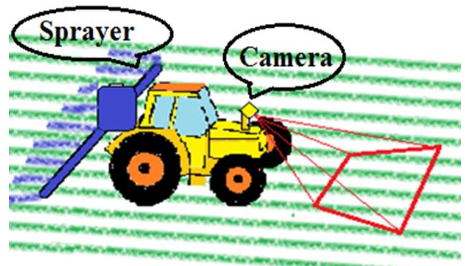
In this research paper, a smart herbicide application system based on a direct-injection sprayer was developed on an autonomous unmanned tractor.
References
[1] bilberry.io/
[2] Agrifac/
[3] Adil Tannouche, Khalid Sbai, Miloud Rahmoune, Rachid Agounoune, Abdelhai Rahmani, Abdelali Rahmani (2016) Real Time Weed Detection using a Boosted Cascade of Simple Features. International Journal of Electrical and Computer Engineering (IJECE) Vol. 6, No. 6, December 2016, pp. 2755~2765
[4] robohub.org
[5] Jing-Lei Tang, Xiao-Qian Chen, Rong-Hui Miao, Dong Wang (2015) Weed detection using image processing under different illumination for site-specific areas spraying. Computers and Electronics in Agriculture Volume 122, March 2016, Pages 103-111
[6] Mariano Gonzalez-de-Soto, Luis Emmi, Manuel Perez-Ruiz, Juan Aguera, Pablo Gonzalez-de-Santos (2016) Autonomous systems for precise spraying – Evaluation of a robotised patch sprayer. Biosystems Engineering Volume 146, June 2016, Pages 165-182
[7] WEEDit
[8] See and Spray